VERT.SV
- DOMAIN
- INTEGRATION
- OUTPUT
- KINETIC PROTOTYPE
- ROLE
- HARDWARE/ROBOTICS DESIGNER
- TIME/PLACE
- JAN 2025 / LOS ANGELES
- COLLABORATOR
- N/A
- SOFTWARE
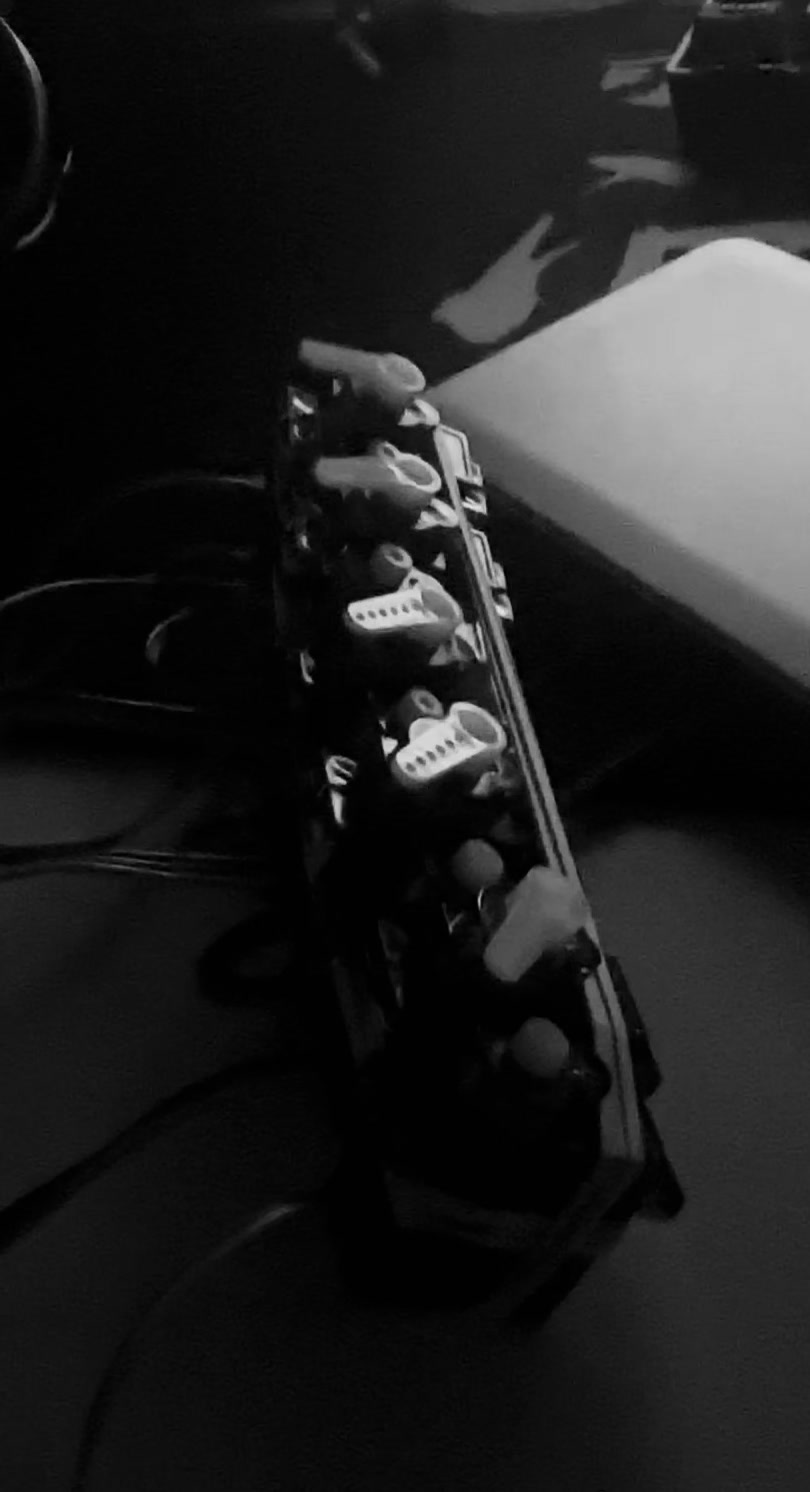
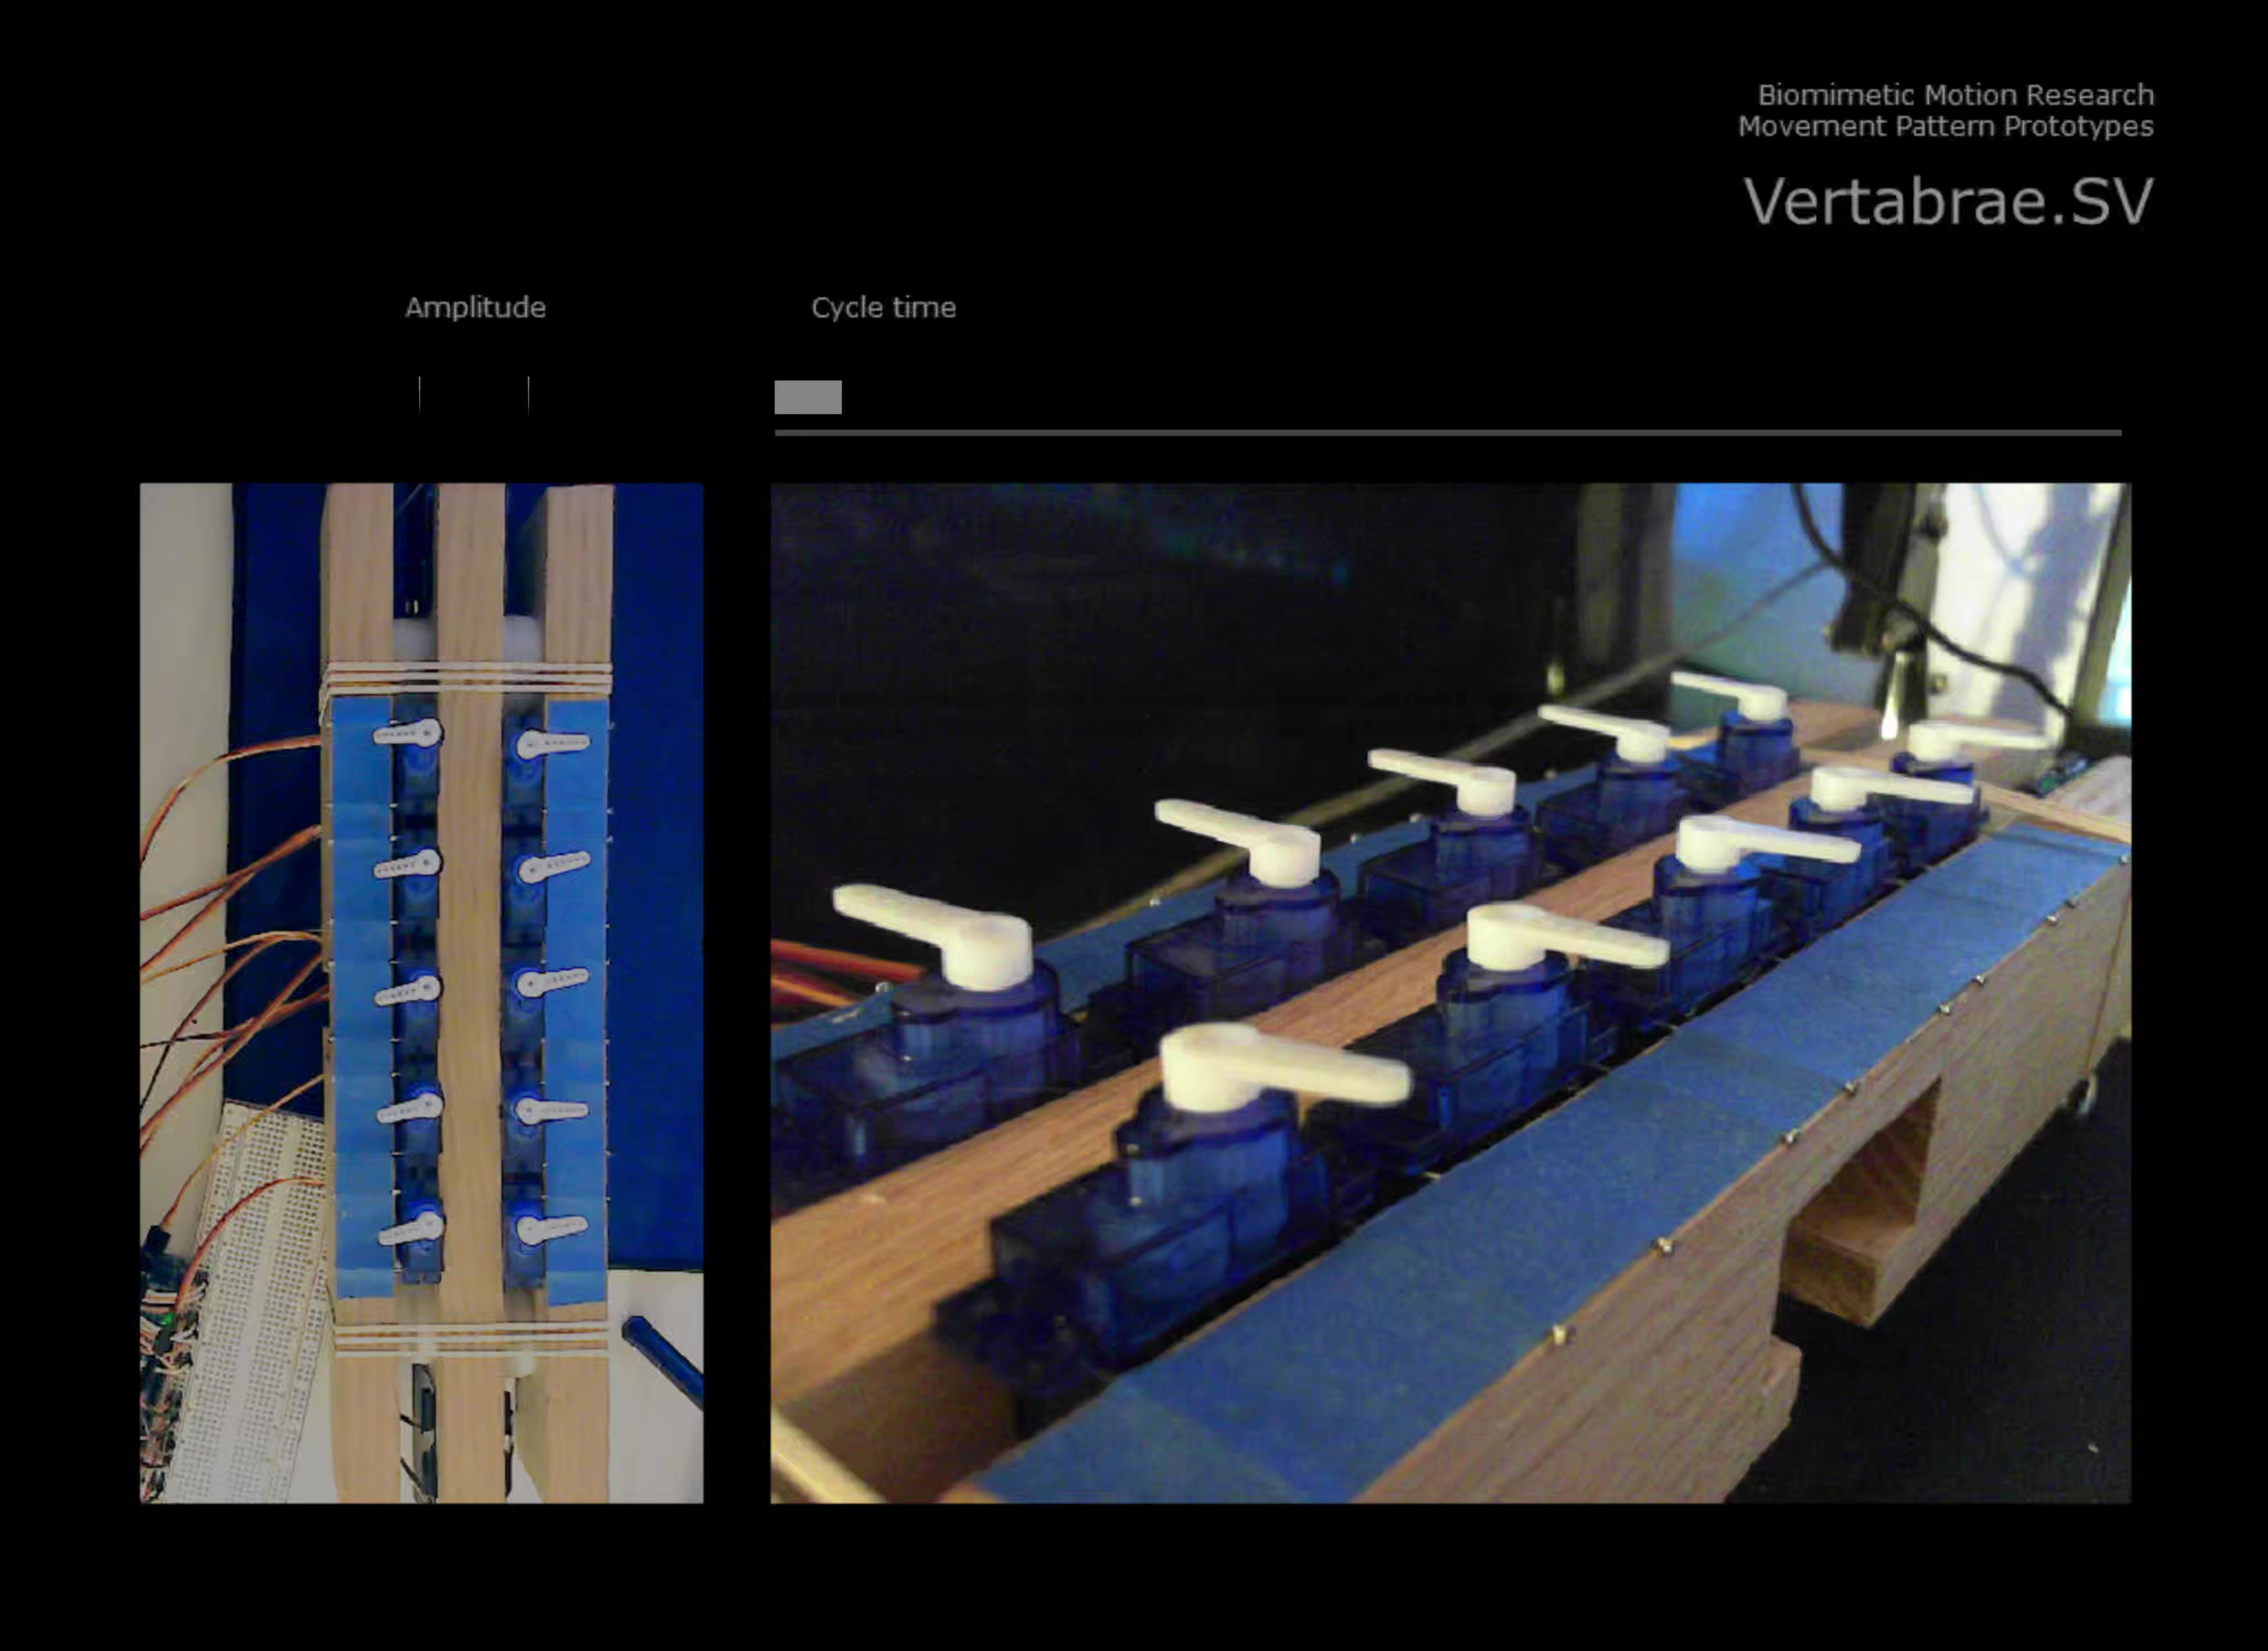
Vertebrae.Servo is a real-time technical prototype exploring robotics movement and web integrated controllers for applications towards kinetic sculptures/installations. The final integration features variations of motion patterns for two mirroring arrays of Arduino servos, while extending the span and speed parameters to the front end through serial communication and WebSocket. Final output controllers are demonstrated within this page.
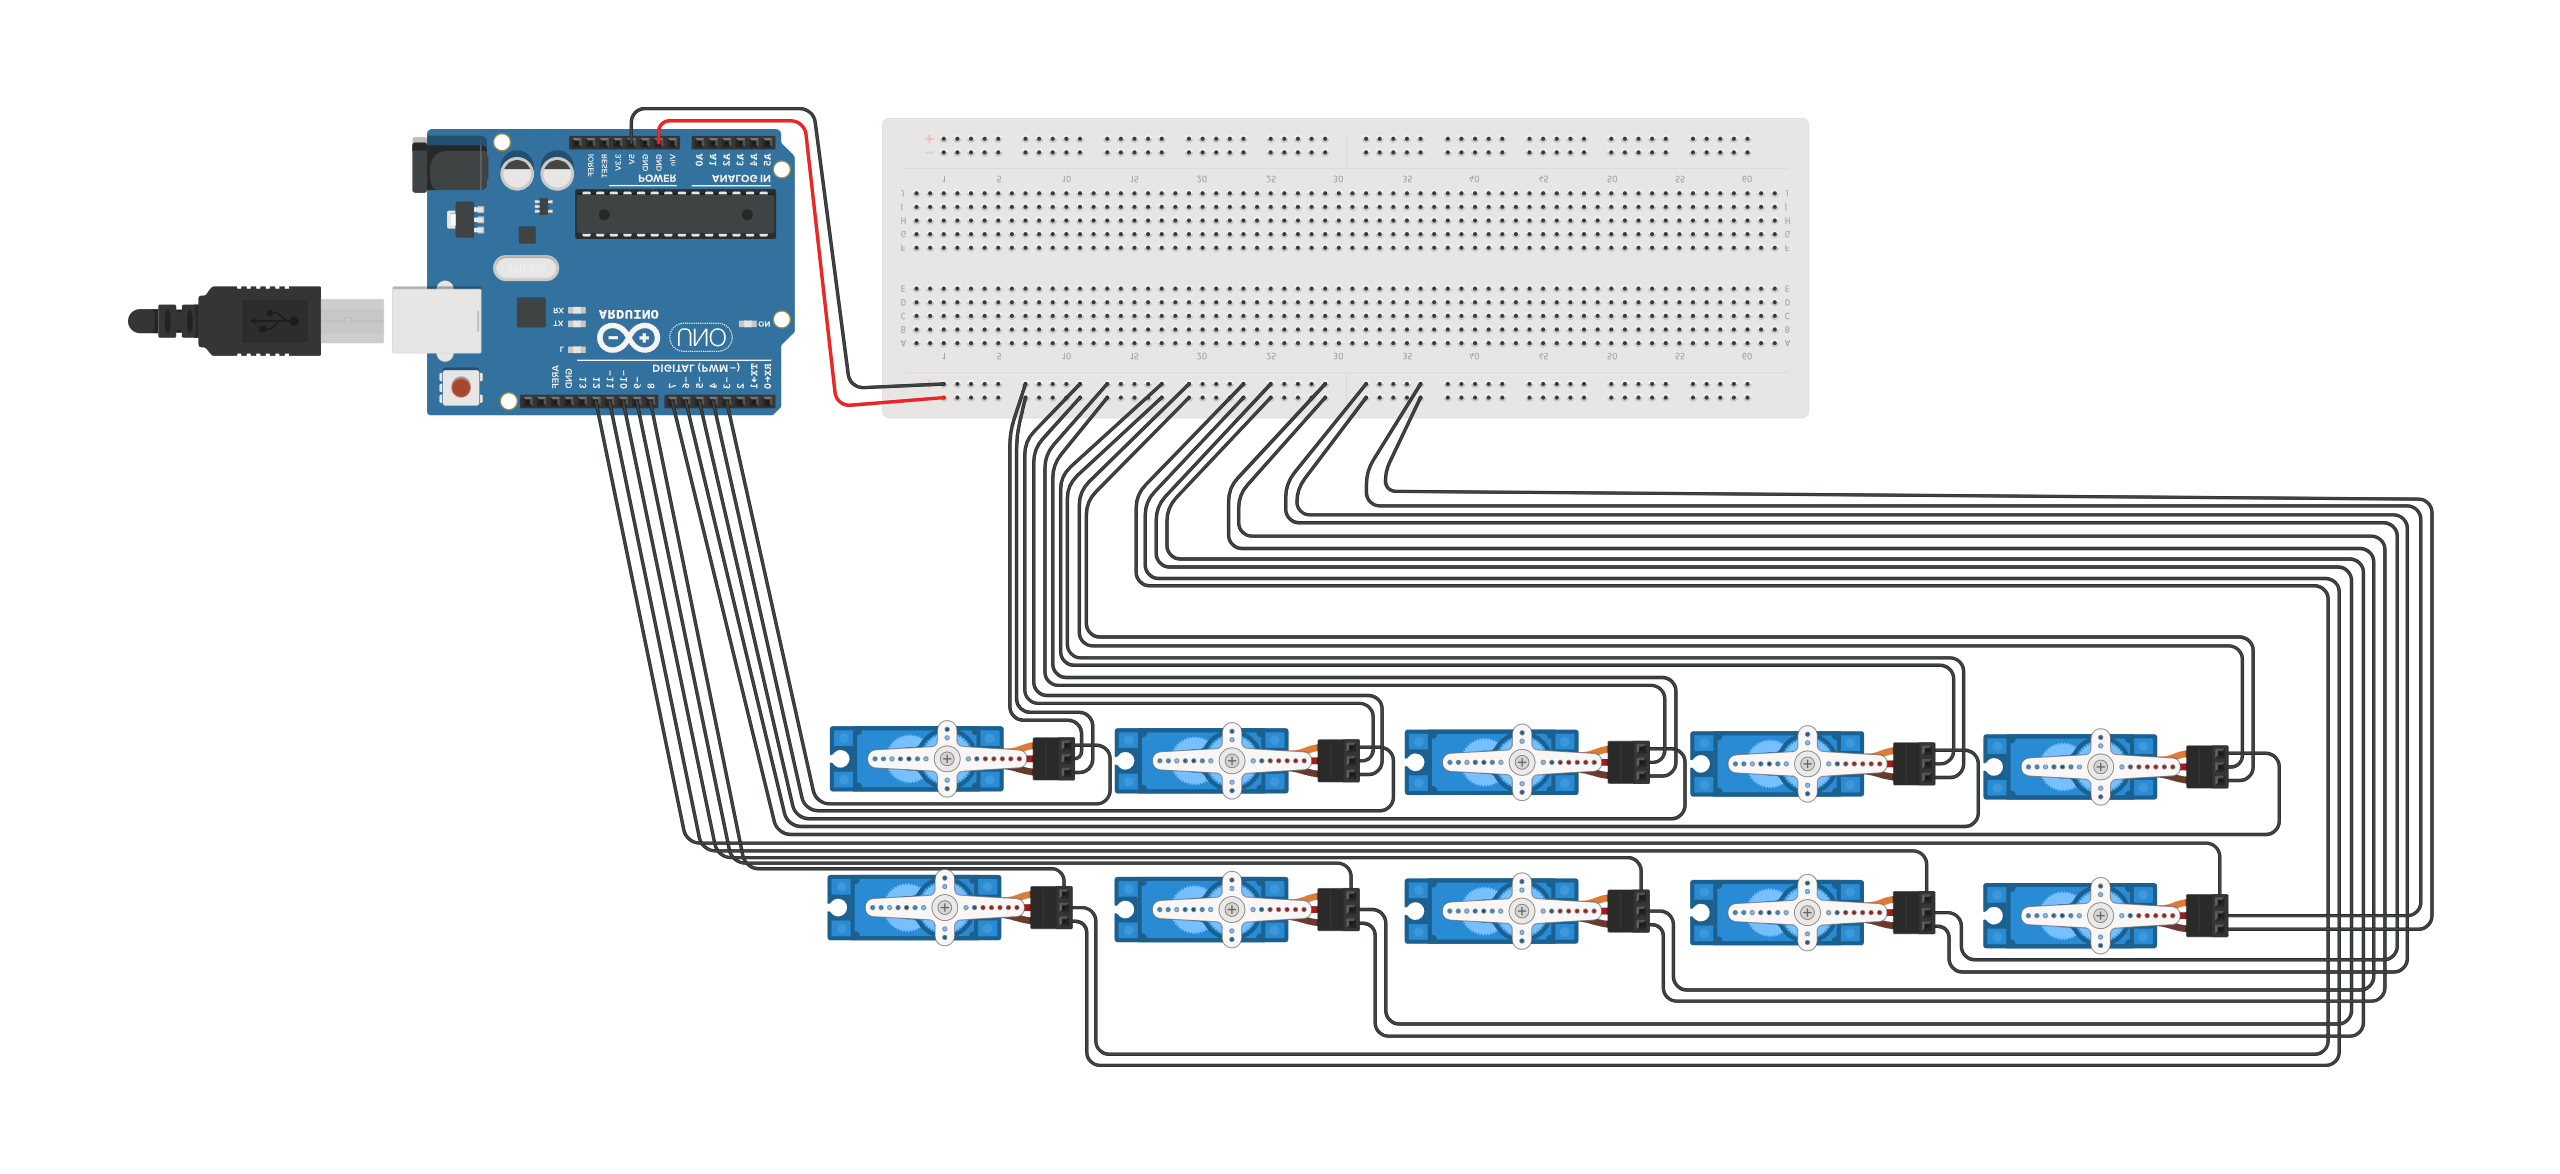
As a personal study, this project included two iterative phases that defined the design process: Phase one focused on establishing a fundamental system for exploring automated motion loops for the Arduino Servos. Phase two took priority in developing an end to end communication within TouchDesigner. The hardware and wiring set-up is additional documented through TinkerCad and Fusion360.
- INTEGRATIONSWEBSOCKET / SERVO ARRAYS / MOTION SCRIPTS
- RT FLOWSIGNALS / SYSTEM / DUAL CHANNEL CONTROL
- OUTPUTWIRING / SPAN / SPEED
- INPUT PROCESSINGINTERNAL TD / SERIAL MSGS
- MONITOR / OUTPUTMONITOR FEEDBACK / ARDUINO MOTION
macro frequency for one repetition
dual-channel framework where each row operates independently, allowing precise manipulation of left and right span width.
the system also includes a speed control feature that synchronously monitors signals processed through TouchDesigner.